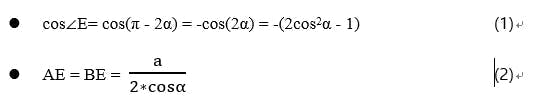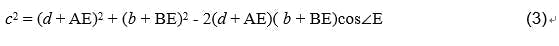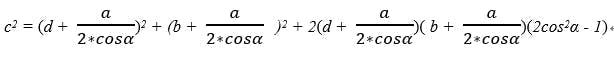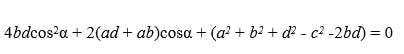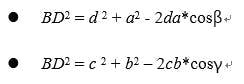Kendali Jarak Jauh Robot Arm Arduino 6-DOF melalui Antarmuka Web
Komponen dan Perlengkapan
Arduino UNO – 1 unit
PHPoC WiFi Shield for Arduino – 1 unit
6DOF Arm Robot – 1 unit
Tentang Proyek Ini
Jika Anda pemula, saya merekomendasikan untuk membaca tutorial berikut:
Arduino - Motor
Arduino - Servo Motor
Arduino - Wifi
1. Demonstrasi
2. Antarmuka Pengguna
Robot arm memiliki 6 motor.
Zone A: Kontrol motor 2, 3, 4 (kontrol tiga sendi tangan)
Zone B: Kontrol motor 1 (kontrol basis)
Zone C: Kontrol motor 5 (kontrol rotasi gripper)
Zone D: Kontrol motor 6 (kontrol gripper)
3. Arsitektur Sistem
4. Alur Kerja
Sisi Klien (antarmuka pengguna web - ditulis dalam JavaScript + HTML + CSS)
Saat pengguna menyentuh atau menyapu jari (atau mengklik atau memindahkan mouse), kita dapat mendapatkan koordinat (x, y). Alur kerja adalah sebagai berikut:
Dalam kasus Zone A, untuk menghitung sudut motor 2, 3, 4, kita perlu melakukan beberapa perhitungan geometri. Anda dapat merujuk ke bagian akhir halaman ini.
Sisi Server (kode Arduino):
Setelah menerima seperangkat sudut dari klien, enam motor bergerak dari sudut saat ini ke sudut baru secara bertahap. Enam motor harus bergerak dan mencapai sudut baru pada saat yang sama. Sebelum memasuki detail cara mengontrol semua motor, mari kita lihat cara mengontrol satu motor. Misalkan kita ingin memindahkan motor dari sudut saat ini (sudut) ke sudut baru (sudut_baru). Karena kecepatan motor tinggi, kita harus melambatkannya. Untuk melakukan seperti itu, dua langkah berikut diulang sampai motor mencapai sudut baru:
Gerakkan motor dengan langkah kecil.
Jeda waktu kecil lalu gerakkan langkah lainnya.
Diagram di bawah ini menggambarkan skema di atas dalam kasus sudut baru lebih besar dari sudut saat ini:
Di mana step_num adalah jumlah langkah yang harus diambil motor. step and time adalah nilai yang telah ditentukan. Kedua yang terakhir menentukan kecepatan dan kehalusan. Di atas hanyalah untuk satu robot. Untuk membuat robot mulai bergerak dan mencapai tujuan pada saat yang sama, kita dapat melakukan sebagai berikut: Enam motor mengambil step_num yang sama, tetapi step dari setiap motor berbeda satu sama lain. Jadi kita harus memilih step_num dalam proyek ini adalah maksimum.
Secara umum, alur kerja Arduino adalah sebagai berikut:
5. Perhitungan Geometri
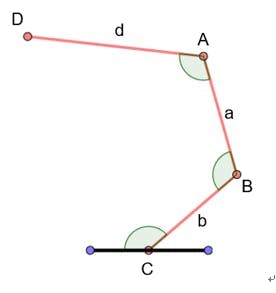
Mari kita buat perhitungan robot arm menjadi masalah geometri berikut:
Diketahui
C tetap
Titik A diketahui - D adalah input dari pengguna
Titik A diketahui - CB, BA, AD (disebut dengan b, a, d masing-masing)
Panjang setiap segmen arm Ditemukan: sudut C, B, A Solusi:
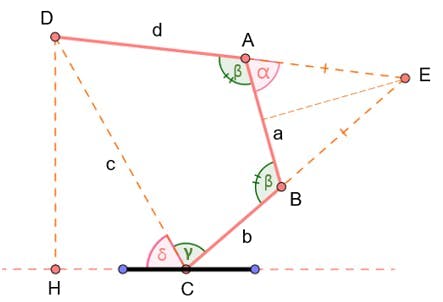
Buat asumsi bahwa sudut B dan A sama
Tambahkan beberapa titik dan segmen tambahan
Perhitungan
Kita mengetahui titik C dan D => kita dapat menghitung panjang DC (disebut c)
Kita juga dapat menghitung δ
Lihat segitiga ABE, kita dapat menyimpulkan bahwa AE = BE dan ∠E = π - 2α.
Jadi:
Hukum Cosinus pada segitiga CDE:
Ubah (1) dan (2) menjadi (3), kita memiliki:
Sederhanakan
Sederhanakan di atas:
Karena kita mengetahui a, b, c dan d, selesaikan persamaan kuadrat di atas, kita dapat menghitung nilai α. - Dan β = π – α - Hingga sekarang kita menemukan β, mari kita cari γ - Hukum Cosinus pada segitiga BDC dan BDA:
Selesaikan himpunan persamaan ini, kita dapat menghitung γ.
Jadi, sudut yang diperlukan adalah: (δ+γ), β dan β. Ini adalah sudut motor 2, 3 dan 4, masing-masing.
6. Kode Sumber
Kode sumber mencakup dua file:
RobotArmWeb.ino: Kode Arduino
Remote_arm.php: Kode aplikasi web, yang diunggah ke PHPoC WiFi Shield atau PHPoC Shield. (Lihat petunjuk dalam artikel ini.)
Anda juga perlu mengunggah file gambar flywheel.png ke PHPoC Shield.
The Best Arduino Starter Kit for Beginner
Jika Anda mencari kit Arduino, lihat The Best Arduino Kit for Beginners
Function References
Arduino - Servo Library
Servo.attach()
Servo.write()
Servo.writeMicroseconds()
Servo.read()
Servo.attached()
Servo.detach()
Serial.begin()
Serial.println()
Kode
RobotArmWeb
remote_arm.php
RobotArmWebArduino
Ini adalah Kode Arduino
#include <Phpoc.h> #include <Servo.h> int angle_init[] = {90, 101, 165, 153, 90, 120}; // when motor stands straight. In web, the angle when motor stands straight is {0, 90, 130, 180, 0, 0}; int angle_offset[] = {0, 11, -15, -27, 0, 137}; // offset between real servo motor and angle on web int cur_angles[] = {90, 101, 165, 153, 90, 120}; // current angles of six motors (degree) int dest_angles[] = {0, 0, 0, 0, 0, 0}; // destined angles int angle_max[] = {180, 180, 160, 120, 180, 137}; int angle_min[] = { 0, 0, 0, 20, 0, 75}; int direction[] = {1, 1, 1, 1, 1 ,-1}; int angleSteps[] = {3, 2, 2, 2, 4 ,4}; // moving steps of each motor (degree) Servo servo1; Servo servo2; Servo servo3; Servo servo4; Servo servo5; Servo servo6; Servo servo[6] = {servo1, servo2, servo3, servo4, servo5, servo6}; PhpocServer server(80); PhpocClient client; int stepNum = 0; void setup(){ Serial.begin(9600); Phpoc.begin(PF_LOG_SPI | PF_LOG_NET); server.beginWebSocket("remote_arm"); servo1.attach(2); // attaches the servo on pin 2 to the servo object servo2.attach(3); // attaches the servo on pin 3 to the servo object servo3.attach(4); // attaches the servo on pin 4 to the servo object servo4.attach(5); // attaches the servo on pin 5 to the servo object servo5.attach(6); // attaches the servo on pin 6 to the servo object servo6.attach(7); // attaches the servo on pin 7 to the servo object for(int i = 0; i < 6; i++) servo[i].write(angle_init[i]); } void loop() { PhpocClient client = server.available(); if(client) { String angleStr = client.readLine(); if(angleStr) { Serial.println(angleStr); int commaPos1 = -1; int commaPos2; for(int i = 0; i < 5; i++) { commaPos2 = angleStr.indexOf(',', commaPos1 + 1); int angle = angleStr.substring(commaPos1 + 1, commaPos2).toInt(); dest_angles[i] = angle * direction[i] + angle_offset[i]; commaPos1 = commaPos2; } int angle5 = angleStr.substring(commaPos1 + 1).toInt(); dest_angles[5] = angle5 * direction[5] + angle_offset[5]; stepNum = 0; // move motors in many small steps to make motor move smooth, avoiding move motor suddently. The below is step calculation for(int i = 0; i < 6; i++) { int dif = abs(cur_angles[i] - dest_angles[i]); int step = dif / angleSteps[i]; if(stepNum < step) stepNum = step; } } } // move motors step by step if(stepNum > 0) { for(int i = 0; i < 6; i++) { int angleStepMove = (dest_angles[i] - cur_angles[i]) / stepNum; cur_angles[i] += angleStepMove; if(cur_angles[i] > angle_max[i]) cur_angles[i] = angle_max[i]; else if(cur_angles[i] < angle_min[i]) cur_angles[i] = angle_min[i]; servo[i].write(cur_angles[i]); } stepNum--; delay(20); } }
remote_arm.phpPHP
Ini adalah aplikasi web.
<!DOCTYPE html> <html> <head> <title>Arduino - Arm Robot - Web</title> <meta name="viewport" content="width=device-width, initial-scale=0.9"> <style> body { text-align: center; } canvas { background-color: #FFFFFF; } </style> <script> var MOTOR_1 = 0; var MOTOR_2 = 1; var MOTOR_3 = 2; var MOTOR_4 = 3; var MOTOR_5 = 4; var MOTOR_6 = 5; var ARM_LENGTH_1 = 95; var ARM_LENGTH_2 = 88; var ARM_LENGTH_3 = 155; var SOLE_WIDTH = 160; var SOLE_HEIGHT = 73; var flywheel_img = new Image(); flywheel_img.src = "flywheel.png"; var zone_A_radius = ARM_LENGTH_1 + ARM_LENGTH_2 + ARM_LENGTH_3; var pivot_x = zone_A_radius + 5; var pivot_y = zone_A_radius + 5; var zone_B_radius = 100; var zone_B_center_x = pivot_x / 2; var zone_B_center_y = -(zone_B_radius + SOLE_HEIGHT + 20); var zone_B_last_angle = 0; var zone_C_radius = 70; var zone_C_center_x = -pivot_x / 2; var zone_C_center_y = -(zone_B_radius + SOLE_HEIGHT + 20); var zone_C_last_angle = 0; var zone_D_width = 30; var zone_D_height = 200.0; var zone_D_center_x = 0; var zone_D_center_y = -(zone_B_radius + SOLE_HEIGHT + 110); var grip_height = 70; var grip_width = 100; var canvas_width = zone_A_radius * 2 + 10; var canvas_height = zone_A_radius + SOLE_HEIGHT + zone_B_radius * 2 + 180; var grip_max_angle = 62.0; // 62 degree var click_state = 0; var mouse_xyra = {x:0, y:0, r:0.0, a:0.0}; var angles = [90, 90, 180, 180, 90, 17]; var ws = null; var servo = null, ctx = null; var last_time; var a = 0, b = 0, c = 0; function init() { servo = document.getElementById("servo"); servo.width = canvas_width; servo.height = canvas_height; servo.addEventListener("touchstart", mouse_down); servo.addEventListener("touchend", mouse_up); servo.addEventListener("touchmove", mouse_move); servo.addEventListener("mousedown", mouse_down); servo.addEventListener("mouseup", mouse_up); servo.addEventListener("mousemove", mouse_move); ctx = servo.getContext("2d"); ctx.translate(pivot_x, pivot_y); ctx.rotate(Math.PI); // quadratic equation parameters a = 4*ARM_LENGTH_1*ARM_LENGTH_3; b = 2*(ARM_LENGTH_2*ARM_LENGTH_1 + ARM_LENGTH_2*ARM_LENGTH_3); c = Math.pow(ARM_LENGTH_1, 2) + Math.pow(ARM_LENGTH_2, 2) + Math.pow(ARM_LENGTH_3, 2) - 2*ARM_LENGTH_1*ARM_LENGTH_3; } function update_view() { ctx.clearRect(-canvas_width/2, -SOLE_HEIGHT, canvas_width, canvas_height); ctx.save(); //draw zone A ctx.fillStyle = "#D9D9D9"; ctx.beginPath(); ctx.arc(0,0,zone_A_radius, 0, 2*Math.PI); ctx.fill(); ctx.fillStyle = "#FFFFFF"; ctx.fillRect(-pivot_x , -canvas_height + pivot_y, canvas_width, canvas_height - pivot_y - SOLE_HEIGHT); // draw arm segments ctx.strokeStyle="#00979D"; ctx.fillStyle = "#FF4500"; ctx.lineWidth = 20; ctx.rotate(angles[MOTOR_2] / 180 * Math.PI); ctx.beginPath(); ctx.moveTo(0,0); ctx.lineTo(ARM_LENGTH_1,0); ctx.stroke(); draw_pivot(0, 0); ctx.translate(ARM_LENGTH_1,0); ctx.rotate(-Math.PI + angles[MOTOR_3] / 180 * Math.PI); ctx.beginPath(); ctx.moveTo(0,0); ctx.lineTo(ARM_LENGTH_2, 0); ctx.stroke(); draw_pivot(0, 0); ctx.translate(ARM_LENGTH_2,0); ctx.rotate(-Math.PI + angles[MOTOR_4] / 180 * Math.PI); ctx.beginPath(); ctx.moveTo(0,0); ctx.lineTo(ARM_LENGTH_3, 0); ctx.stroke(); draw_pivot(0, 0); ctx.restore(); ctx.strokeStyle = "#00979D"; ctx.lineWidth = 6; // draw zone B angle = (angles[MOTOR_1] + 45) * Math.PI / 180; ctx.save(); ctx.translate(zone_B_center_x, zone_B_center_y); ctx.rotate(angle); ctx.drawImage(flywheel_img, - zone_B_radius, - zone_B_radius, zone_B_radius * 2, zone_B_radius * 2); ctx.beginPath(); ctx.arc(0, 0, zone_B_radius, 0, 2 * Math.PI); ctx.stroke(); ctx.restore(); // draw zone C angle = (angles[MOTOR_5] + 45) * Math.PI / 180; ctx.save(); ctx.translate(zone_C_center_x, zone_C_center_y); ctx.rotate(angle); ctx.drawImage(flywheel_img, - zone_C_radius, - zone_C_radius, zone_C_radius * 2, zone_C_radius * 2); ctx.beginPath(); ctx.arc(0, 0, zone_C_radius, 0, 2 * Math.PI); ctx.stroke(); ctx.restore(); // draw zone D ctx.fillStyle = "#00DEE6"; ctx.lineWidth = 15; var grip_dist = Math.floor(angles[MOTOR_6] / grip_max_angle * zone_D_height); ctx.fillRect(zone_D_center_x - zone_D_width / 2, zone_D_center_y - zone_D_height / 2, zone_D_width, zone_D_height); ctx.lineWidth = 1; ctx.strokeStyle = "#FFFFFF"; var center_x = zone_D_center_x; var center_y = zone_D_center_y + grip_dist / 2; var grd = ctx.createLinearGradient(center_x, center_y, center_x, center_y + grip_height); grd.addColorStop(0,"#004A4D"); grd.addColorStop(1,"#b3fcff"); ctx.fillStyle = grd; ctx.beginPath(); ctx.moveTo(center_x + grip_width / 2, center_y); ctx.bezierCurveTo(center_x + grip_width / 4, center_y + grip_height, center_x - grip_width / 4, center_y + grip_height,center_x - grip_width / 2, center_y); ctx.closePath(); ctx.fill(); ctx.stroke(); center_x = zone_D_center_x; center_y = zone_D_center_y - grip_dist / 2; grd = ctx.createLinearGradient(center_x, center_y, center_x, center_y - grip_height); grd.addColorStop(0,"#004A4D"); grd.addColorStop(1,"#b3fcff"); ctx.fillStyle = grd; ctx.beginPath(); ctx.moveTo(center_x + grip_width / 2, center_y); ctx.bezierCurveTo(center_x + grip_width / 4, center_y - grip_height, center_x - grip_width / 4, center_y - grip_height,center_x - grip_width / 2, center_y); ctx.closePath(); ctx.fill(); ctx.stroke(); ctx.restore(); // draw sole ctx.fillStyle = "#006468"; ctx.fillRect(-SOLE_WIDTH/2, -SOLE_HEIGHT, SOLE_WIDTH, SOLE_HEIGHT); } function event_handler(event) { var x, y, r, alpha; // convert coordinate if(event.touches) { var touches = event.touches; x = (touches[0].pageX - touches[0].target.offsetLeft) - pivot_x; y = (touches[0].pageY - touches[0].target.offsetTop) - pivot_y; } else { x = event.offsetX - pivot_x; y = event.offsetY - pivot_y; } x = -x; y = -y; //check whether it's located in zone A or not r = Math.sqrt(x * x + y * y); if(r < zone_A_radius && y > -SOLE_HEIGHT) { if((x < SOLE_WIDTH/2) && (x > -SOLE_WIDTH/2) && (y < 0)) return false; alpha = Math.atan2(y, x); if(alpha < 0) alpha += 2*Math.PI; mouse_xyra.x = x; mouse_xyra.y = y; mouse_xyra.r = r; mouse_xyra.a = alpha; if(geometric_calculation()) return true; } //check whether it's located in zone B or not temp_x = x - zone_B_center_x; temp_y = y - zone_B_center_y; var distance = Math.sqrt(temp_x * temp_x + temp_y * temp_y); if(distance < zone_B_radius) { var angle = Math.atan2(temp_y, temp_x)* 180 / Math.PI; if(click_state == 0) zone_B_last_angle = angle; else { if((Math.abs(angle) > 90) && (angle * zone_B_last_angle < 0)) { if(zone_B_last_angle > 0) zone_B_last_angle = -180; else zone_B_last_angle = 180; } angles[MOTOR_1] += Math.floor(angle - zone_B_last_angle); angles[MOTOR_1] = Math.max(0, angles[MOTOR_1]); angles[MOTOR_1] = Math.min(180, angles[MOTOR_1]); zone_B_last_angle = angle; } return true; } //check whether it's located in zone C or not temp_x = x - zone_C_center_x; temp_y = y - zone_C_center_y; var distance = Math.sqrt(temp_x * temp_x + temp_y * temp_y); if(distance < zone_C_radius) { var angle = Math.atan2(temp_y, temp_x)* 180 / Math.PI; if(click_state == 0) zone_C_last_angle = angle; else { if((Math.abs(angle) > 90) && (angle * zone_C_last_angle < 0)) { if(zone_C_last_angle > 0) zone_C_last_angle = -180; else zone_C_last_angle = 180; } angles[MOTOR_5] += Math.floor(angle - zone_C_last_angle); angles[MOTOR_5] = Math.max(0, angles[MOTOR_5]); angles[MOTOR_5] = Math.min(180, angles[MOTOR_5]); zone_C_last_angle = angle; } return true; } //check whether it's located in zone D or not var temp_x = Math.abs(x - zone_D_center_x); var temp_y = Math.abs(y - zone_D_center_y); if(temp_x < (zone_D_width / 2) && temp_y < (zone_D_height / 2)) { var angle = temp_y / (zone_D_height / 2) * grip_max_angle; angles[MOTOR_6] = Math.floor(angle); console.log(angles[MOTOR_6]); return true; } return false; } function geometric_calculation() { var c_ = c - Math.pow(mouse_xyra.r, 2); var delta = b*b - 4*a*c_; if(delta < 0) return false; // no root var x1 = 0, x2 = 0; var x = 0; var cos_C = 0; var alpha = 0, beta = 0, gamma = 0; x1 = (-b + Math.sqrt(delta)) / (2*a); x2 = (-b - Math.sqrt(delta)) / (2*a); x = x1; if(x > 1) return false; alpha = Math.acos(x); alpha = alpha * 180 / Math.PI; beta = 180 - alpha; cos_C = Math.pow(mouse_xyra.r, 2) + Math.pow(ARM_LENGTH_1, 2) - ( Math.pow(ARM_LENGTH_2, 2) + Math.pow(ARM_LENGTH_3, 2) + 2*ARM_LENGTH_2*ARM_LENGTH_3*x ); cos_C = cos_C /(2*mouse_xyra.r*ARM_LENGTH_1); angle_C = Math.acos(cos_C); gamma = (angle_C + mouse_xyra.a) % (2*Math.PI); gamma = gamma * 180 / Math.PI; if(gamma < 0) gamma += 360; if(gamma > 180) { var temp = gamma - mouse_xyra.a * 180 / Math.PI; gamma = gamma - 2* temp; beta = 360 - beta; } if(gamma < 0 || gamma > 180) return false; angles[MOTOR_3] = Math.floor(beta); angles[MOTOR_4] = Math.floor(beta); angles[MOTOR_2] = Math.floor(gamma); return true; } function draw_pivot(x, y) { ctx.beginPath(); ctx.arc(x,y, 10, 0, 2*Math.PI); ctx.stroke(); ctx.fill(); } function ws_onmessage(e_msg) { e_msg = e_msg || window.event; // MessageEvent } function ws_onopen() { document.getElementById("ws_state").innerHTML = "OPEN"; document.getElementById("wc_conn").innerHTML = "Disconnect"; angles_change_notice(); update_view(); } function ws_onclose() { document.getElementById("ws_state").innerHTML = "CLOSED"; document.getElementById("wc_conn").innerHTML = "Connect"; console.log("socket was closed"); ws.onopen = null; ws.onclose = null; ws.onmessage = null; ws = null; } function wc_onclick() { if(ws == null) { ws = new WebSocket("ws://<?echo _SERVER("HTTP_HOST")?>/remote_arm", "text.phpoc"); document.getElementById("ws_state").innerHTML = "CONNECTING"; ws.onopen = ws_onopen; ws.onclose = ws_onclose; ws.onmessage = ws_onmessage; } else ws.close(); } function mouse_down() { if(ws == null) return; if(event.touches && (event.touches.length > 1)) click_state = event.touches.length; if(click_state > 1) return; var state = event_handler(event); if(state) { click_state = 1; angles_change_notice(); } event.preventDefault(); } function mouse_up() { click_state = 0; } function mouse_move() { if(ws == null) return; var d = new Date(); var time = d.getTime(); if((time - last_time) < 50) return; last_time = time; if(event.touches && (event.touches.length > 1)) click_state = event.touches.length; if(click_state > 1) return; if(!click_state) return; var state = event_handler(event); if(state) { click_state = 1; angles_change_notice(); } event.preventDefault(); } function angles_change_notice() { if(ws != null && ws.readyState == 1) { ws.send(angles.join(",") + "\r\n"); update_view(); } } window.onload = init; setTimeout(function(){ update_view();}, 500); </script> </head> <body> <h2>Arduino - Control Arm Robot via Web</h2> <canvas id="servo"></canvas> <p>WebSocket : <span id="ws_state">null</span><br></p> <button id="wc_conn" type="button" onclick="wc_onclick();">Connect</button> </body> </html>
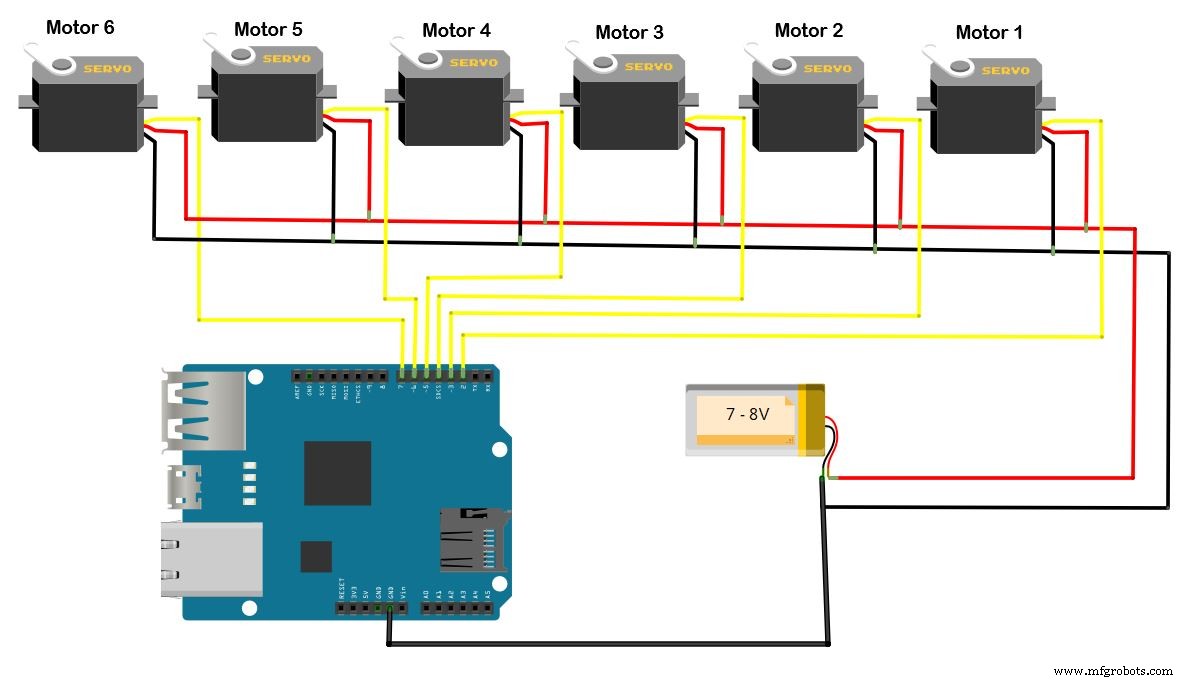
Skematik
It needs to provide the external power source for 6 motors