Robot Industri: Desain, Manufaktur, dan Tren Masa Depan
Latar Belakang
Robot industri adalah precision mechanical systems engineered to replicate human motions with unparalleled consistency. Mereka deployed when safety, strength, accuracy, atau continuous operation surpass what human can achieve. Sebagian besar units are fixed, though mobile robots transport materials dan supplies across shop floor.
Berbeda dengan humanoid figures seen in science fiction, contemporary robots perform basic tasks—picking, placing, welding, atau painting—dengan level of repeatability that humans find difficult to match. Human operators adjust posture dan grip on fly; robot must be designed dan programmed so that position, reach, weight, dan grasp remain strictly controlled to avoid dropping atau missing objects. Once technician “teaches” machine a motion, it can execute motion thousands of times with accuracy of few thousandths of inch, operating 24/7 without fatigue.
These capabilities have driven rapid adoption in manufacturing, particularly for repetitive painting, welding, dan pick-and-place operations that lift dan position products into assembly lines atau packaging stations.
Sejarah
Robotics—a branch of automation—draws its name from Czech word robota, meaning compulsory labor. Term first appeared in 1921 in Karel Čapek’s play R.U.R. (Rossum’s Universal Robots), which imagined humanoid machines that rebelled against creators.
Practical robots emerged after computers became available. In late 1960s, Stanford Research Institute built SHAKEY, machine that could move dan stack blocks using camera dan computer. In mid-1970s, General Motors, through MIT, commissioned Victor Scheinman’s PUMA (Programmable Universal Manipulator for Assembly), marking first industrial robot to enter U.S. production lines. Unimate, installed in GM plant in Trenton, New Jersey in 1961, was first pick-and-place robot to remove hot metal parts from die-casting machine.
Raw Materials
Robots are constructed from common industrial metals—steel, cast iron, dan aluminum—for strength dan machinability. Mobile units often use rubber tires for quiet, reliable traction. Specialized robots for clean rooms, space, atau high-tech applications may incorporate titanium atau carbon-fiber composites untuk weight savings dan corrosion resistance.
Mechanical structure houses hydraulic cylinders atau pressurized air, dengan silicone, rubber, dan braided stainless-steel hoses routing fluid to control valves. Protective covers—flexible neoprene shields atau collapsible bellows—shield exposed parts from paint spray, sparks, dan other hazards. Electronics, including electric motors, linear drives, dan controller (“brain”), are sourced from automation suppliers dan housed in steel cabinets near or on robot.
Proses Manufaktur
Design
- Every robot starts with design phase that incorporates job requirements, speed, environment, hazardous materials, reach, travel path, process variables, human interaction, controller capability, dan potential failure modes. Most manufacturers begin with standard platform dan then customize it to meet application needs.
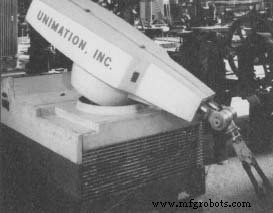 The first robot installed in American industry, Unimate, removed hot metal parts from die-casting machine at GM plant in Trenton, New Jersey, in 1961. (From Henry Ford Museum & Greenfield Village.)
Robots are only as effective as people who design, program, dan maintain them. In 1980s, GM invested heavily in robotics but fell short on systems integration dan workforce training, leading to costly failures dan operational chaos.
Fabrication
- Once designed, base, arms, column, dan supports are fabricated. Base—often cast atau welded—provides heavy foundation to prevent tipping. Components that mate with rest of robot are machined to tight tolerances to ensure proper fit dan function.
Assembly
Industrial robots can contain up to 2,000 individual parts. Assembly teams begin with base dan progressively attach motors, bearings, hydraulics, wiring, dan controllers until robot is ready for testing.
Mobile robots first receive traction motors, batteries, axles, wheels, dan tires. Stationary units are temporarily bolted to floor. Sub-assemblies of columns dan arms, equipped with drive motors, are then integrated onto base. A ring gear drives base’s turning motion, mating with column gear. Thrust bearings support weight, while magnetic scale provides electronic position feedback to controller.
Link
- Link acts as elbow, connecting arm to base. Stabilizer supports dan bearing mounts ensure controlled motion along predetermined path. Each bearing is pre-lubricated atau fitted with lubrication line, dan link houses position sensor that sends data to controller.
Arm
- Arm extends robot’s reach dan supports wrist. It contains drive shafts operated by motors atau hydraulic cylinders. Three motors—or hybrid arrangement—connect to drive shafts, dan large bearings dan pivot pin allow arm dan link joint to bear full load of wrist.
Wrist
- Wrist is core of robot’s manipulation capability, replicating human wrist motion to orient tools—paint guns, welders, atau grippers—in precise positions. Many wrists include load-sensing electronics that detect obstructions atau excessive loads, as well as additional position sensors dan tool-control electronics.
Wiring to Controller
- After mechanical assembly, wiring dan plumbing are completed. All motors, sensors, dan electrical components receive power dan data lines. Hydraulic dan pneumatic hoses supply fluid pressure to cylinders, controlled from valves in base. Wires dan hoses typically route to controller cabinet—mounted on base for mobile units atau few feet away for stationary units via umbilical cord. Protective guards atau shields are added to cover arms dan columns against sparks, paint spray, atau other hazards.
Installation
Installation takes place at customer’s facility. Stationary robots are bolted to floor; mobile robots follow guide wires atau, increasingly, laser-based navigation systems. Fences are erected around mobile units to prevent accidental human contact. After installation, manufacturers provide operation dan maintenance training to client’s staff.
Kontrol Kualitas
Testing comprises functional accuracy checks dan burn-in period. During functional testing, program commands robot through series of motions, recording data to identify dan correct discrepancies. Robot then runs continuously for several hours—burn-in—to detect long-term accuracy loss dan to bring electronics dan hydraulics up to operating temperature. Offset values are calibrated during this phase to compensate for temperature variations dan ensure optimal performance.
Masa Depan
Robotics remains one of fastest-growing segments of industrial machine market. Rapid advances in computing dan artificial intelligence enable newer models to learn dan adapt autonomously. Japanese manufacturers lead in this innovation, integrating AI-driven control systems that allow robots to adjust operations on fly.
Improvements in camera technology dan computer vision will expand robotics into healthcare, food service, dan other domains where robots interact more closely with people, further broadening impact beyond traditional manufacturing floors.



